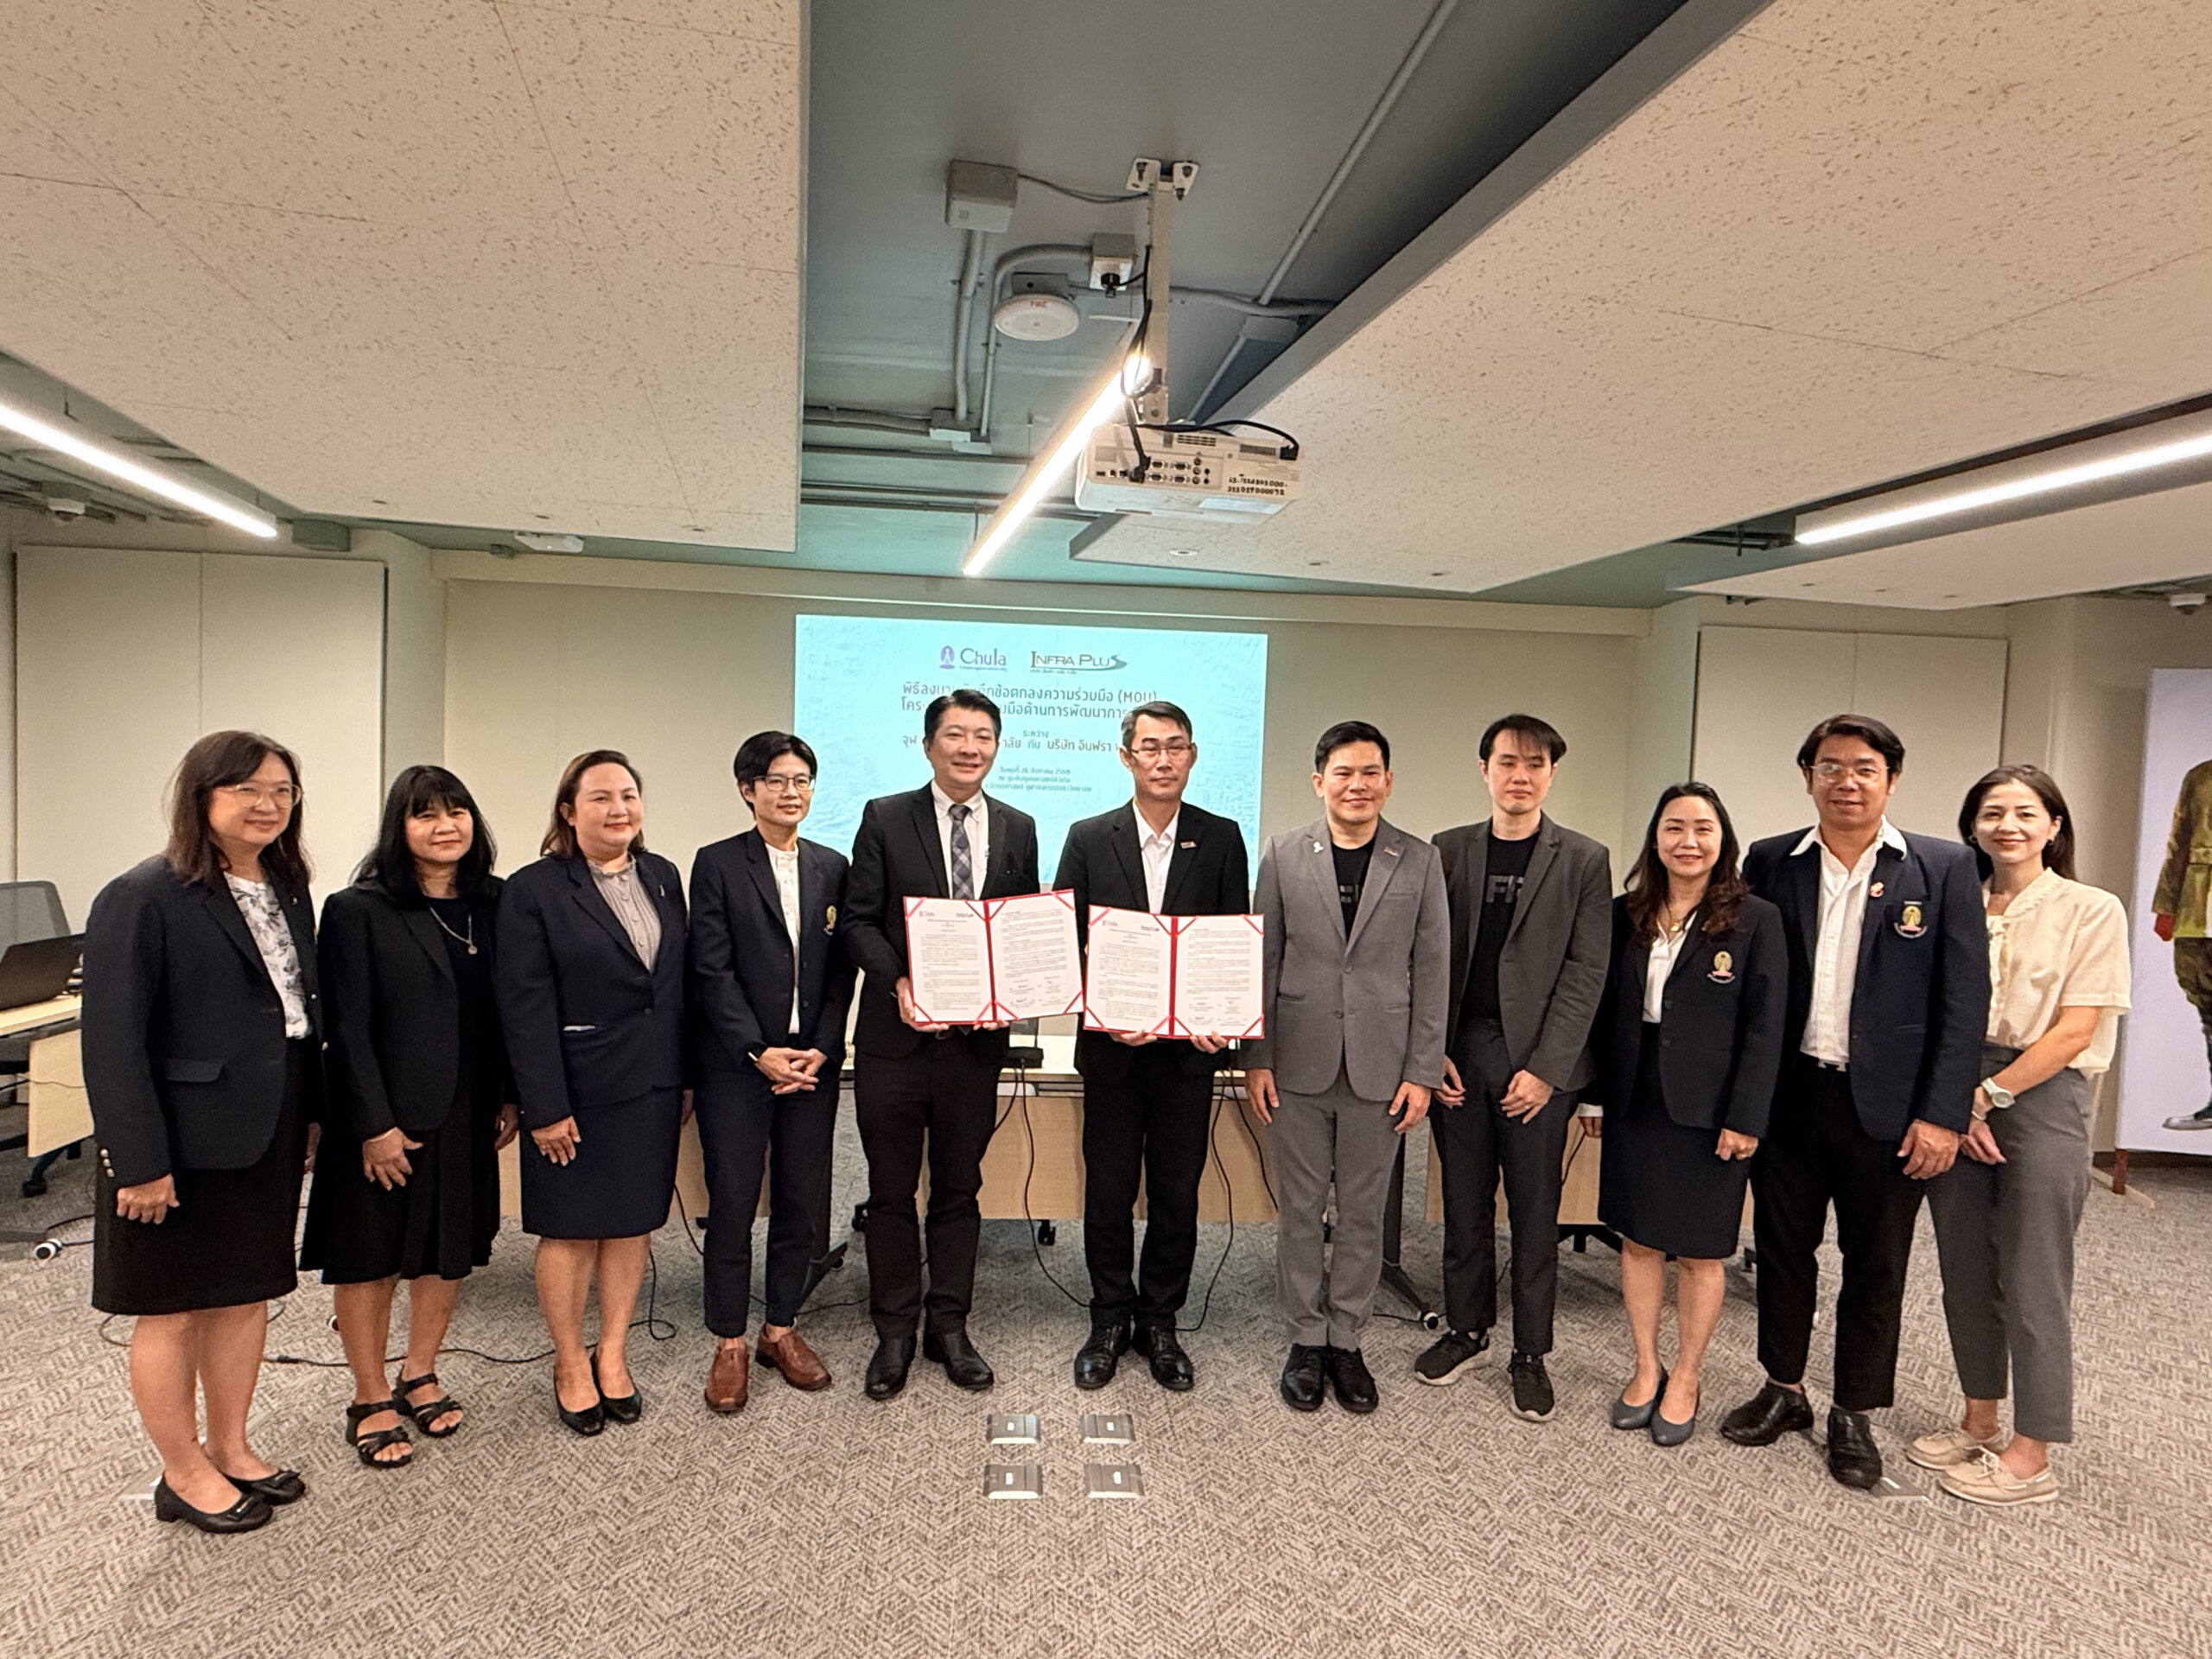
We are committed to fostering growth, sustainability, safety, and quality service for the nation’s infrastructure through the support, promotion, and development of our group of companies.
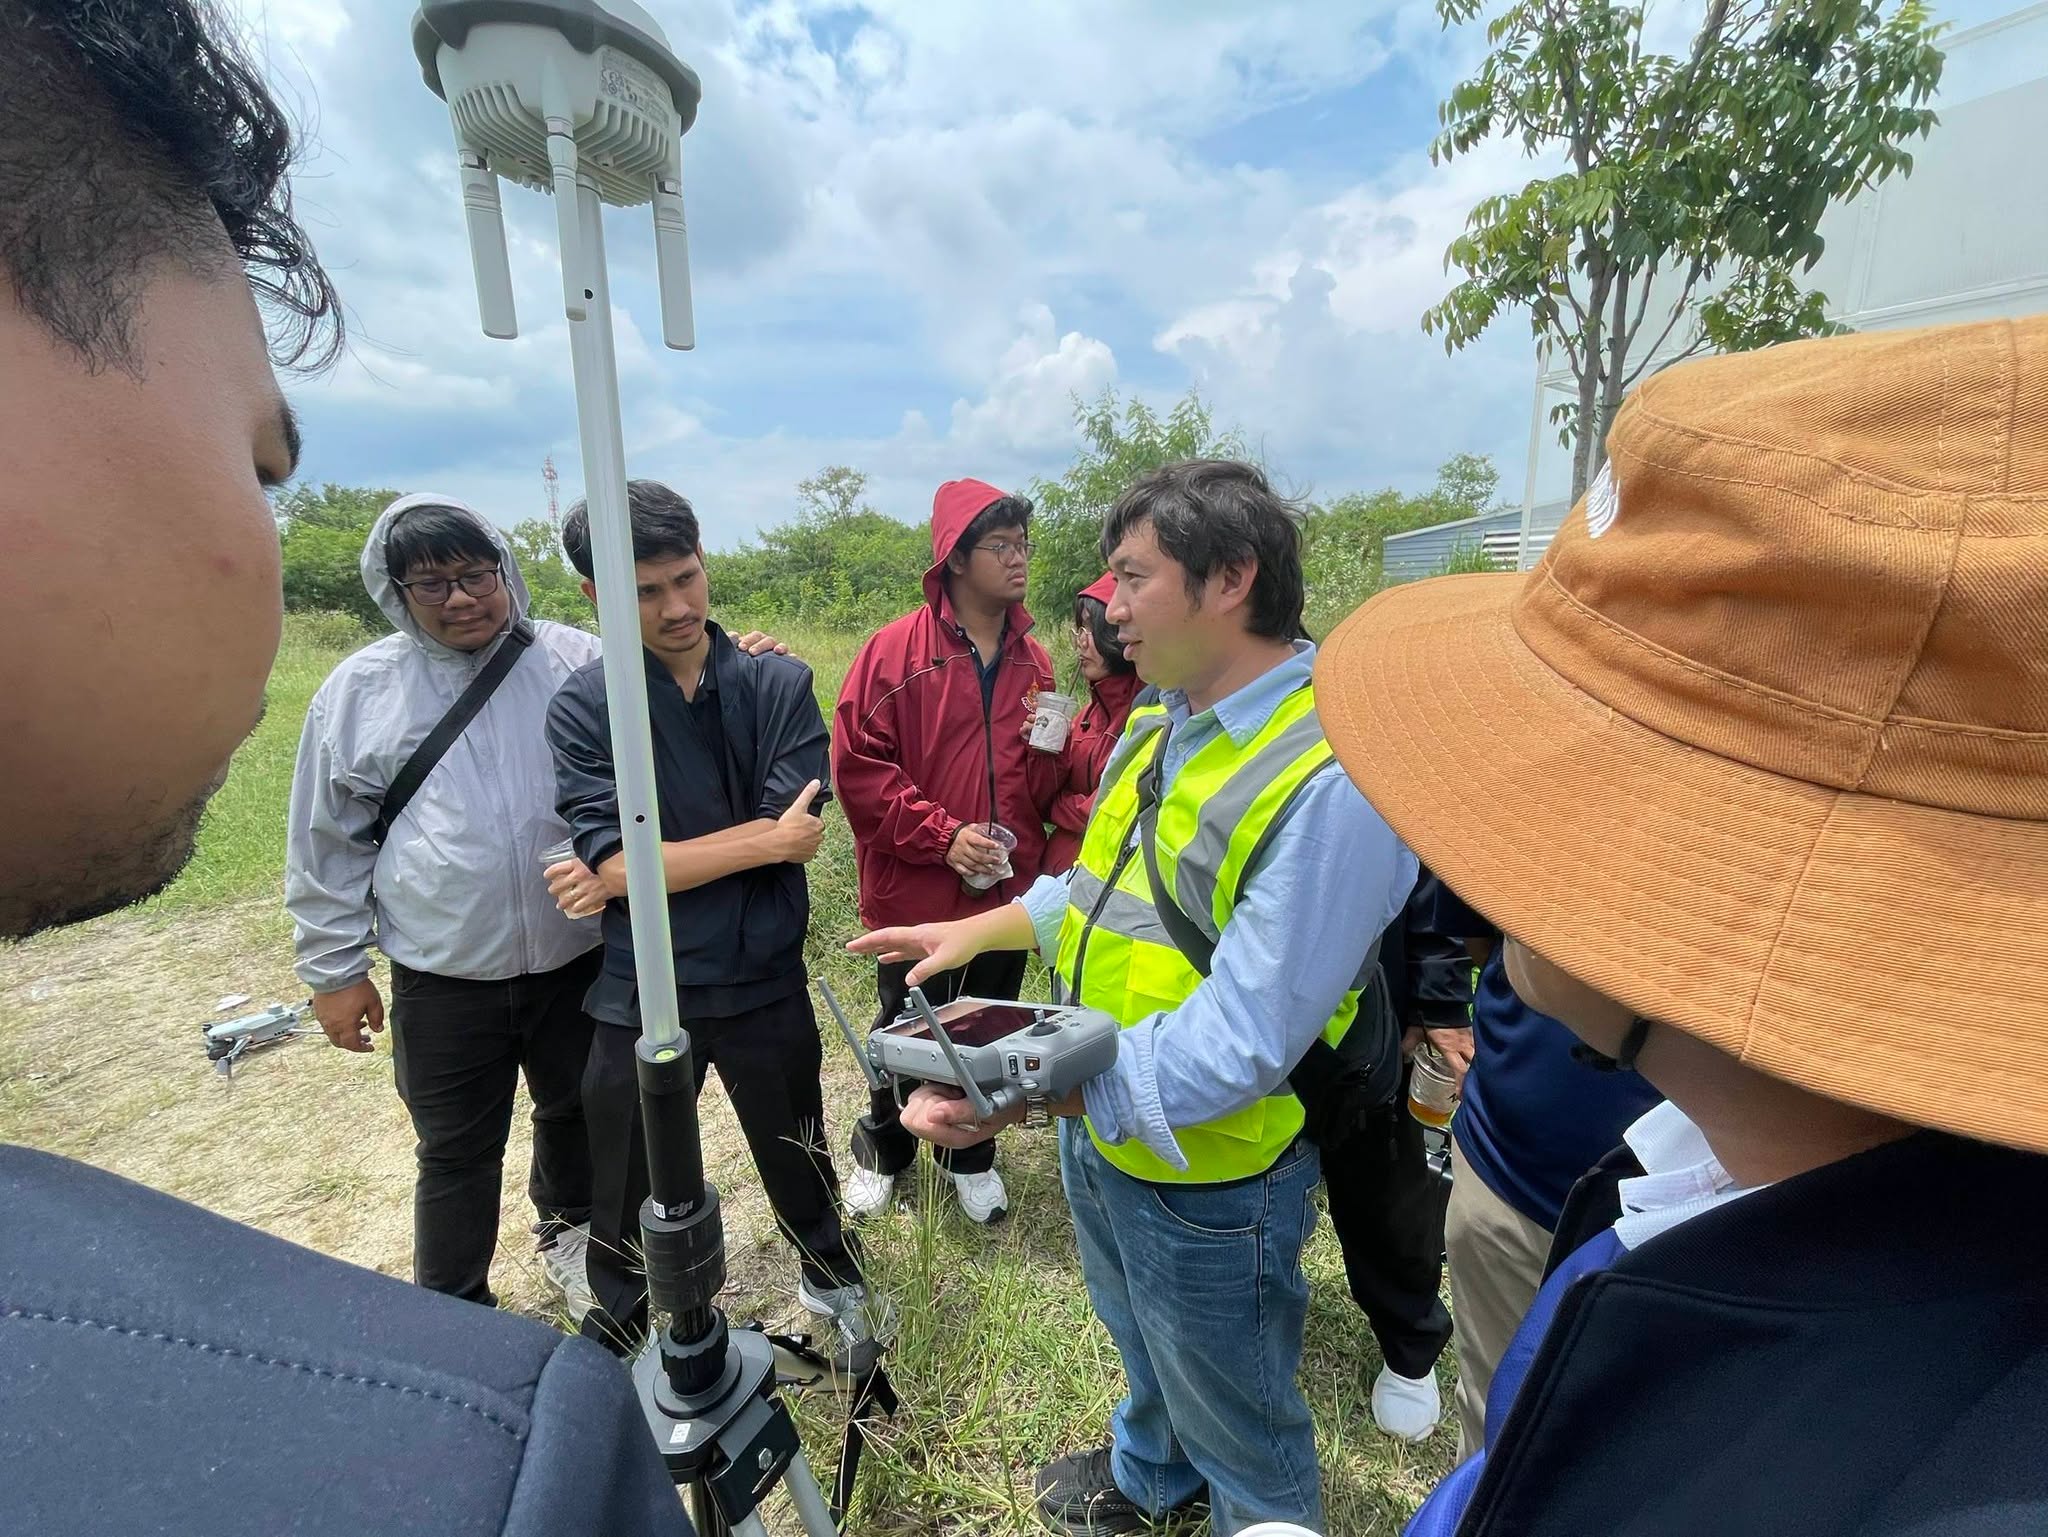
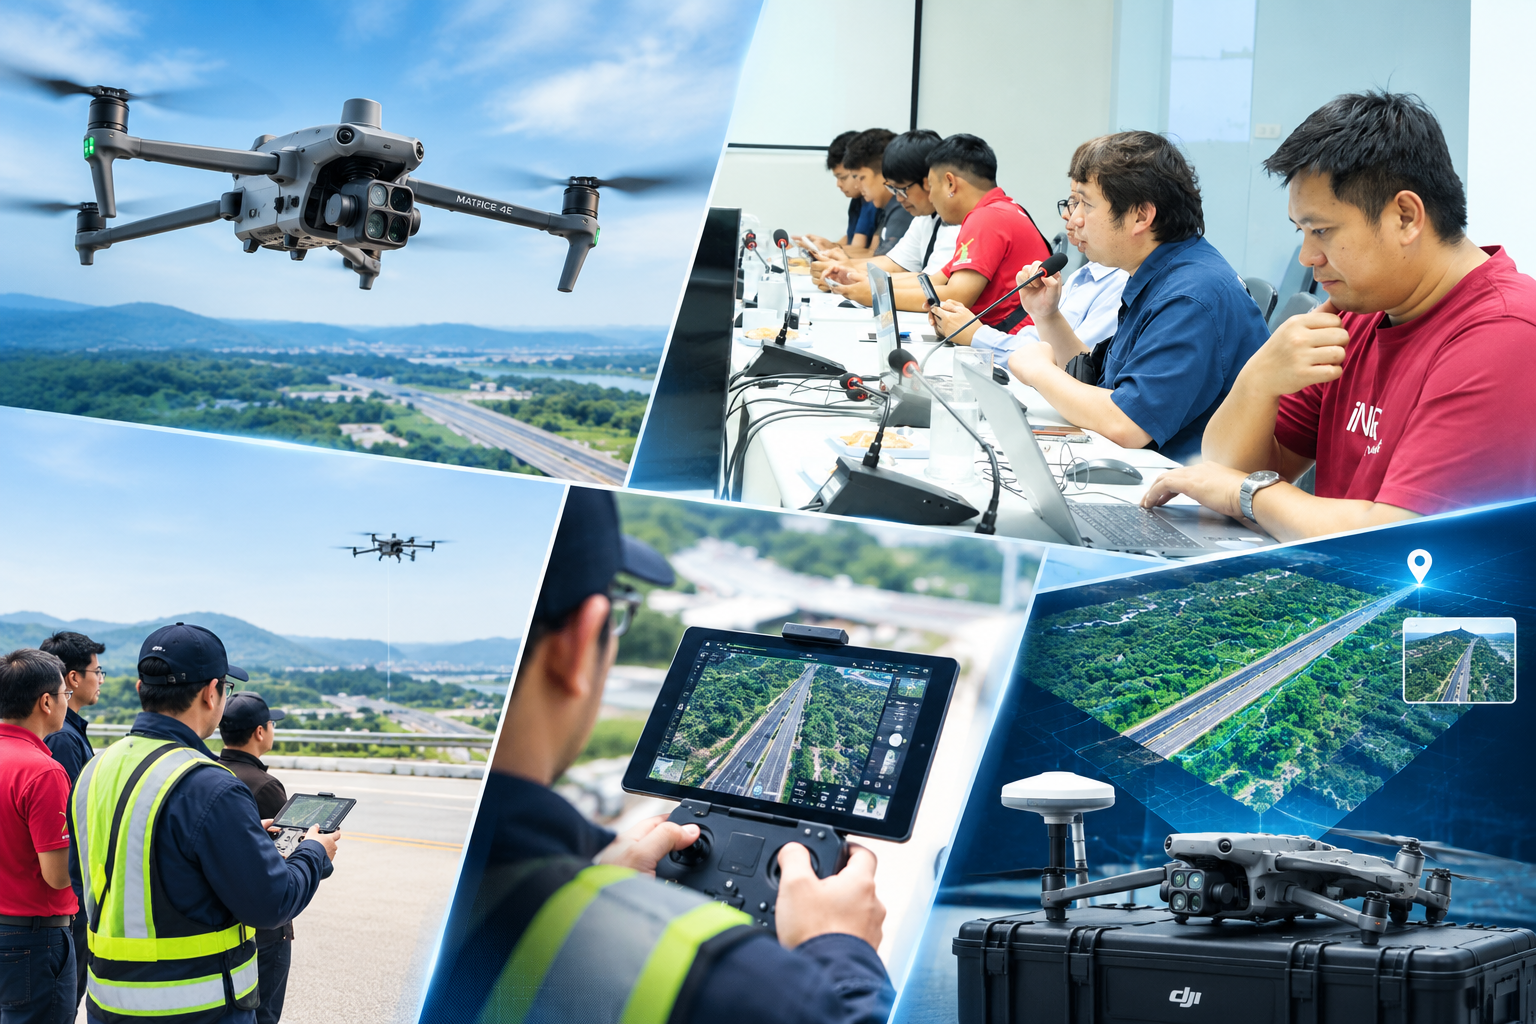
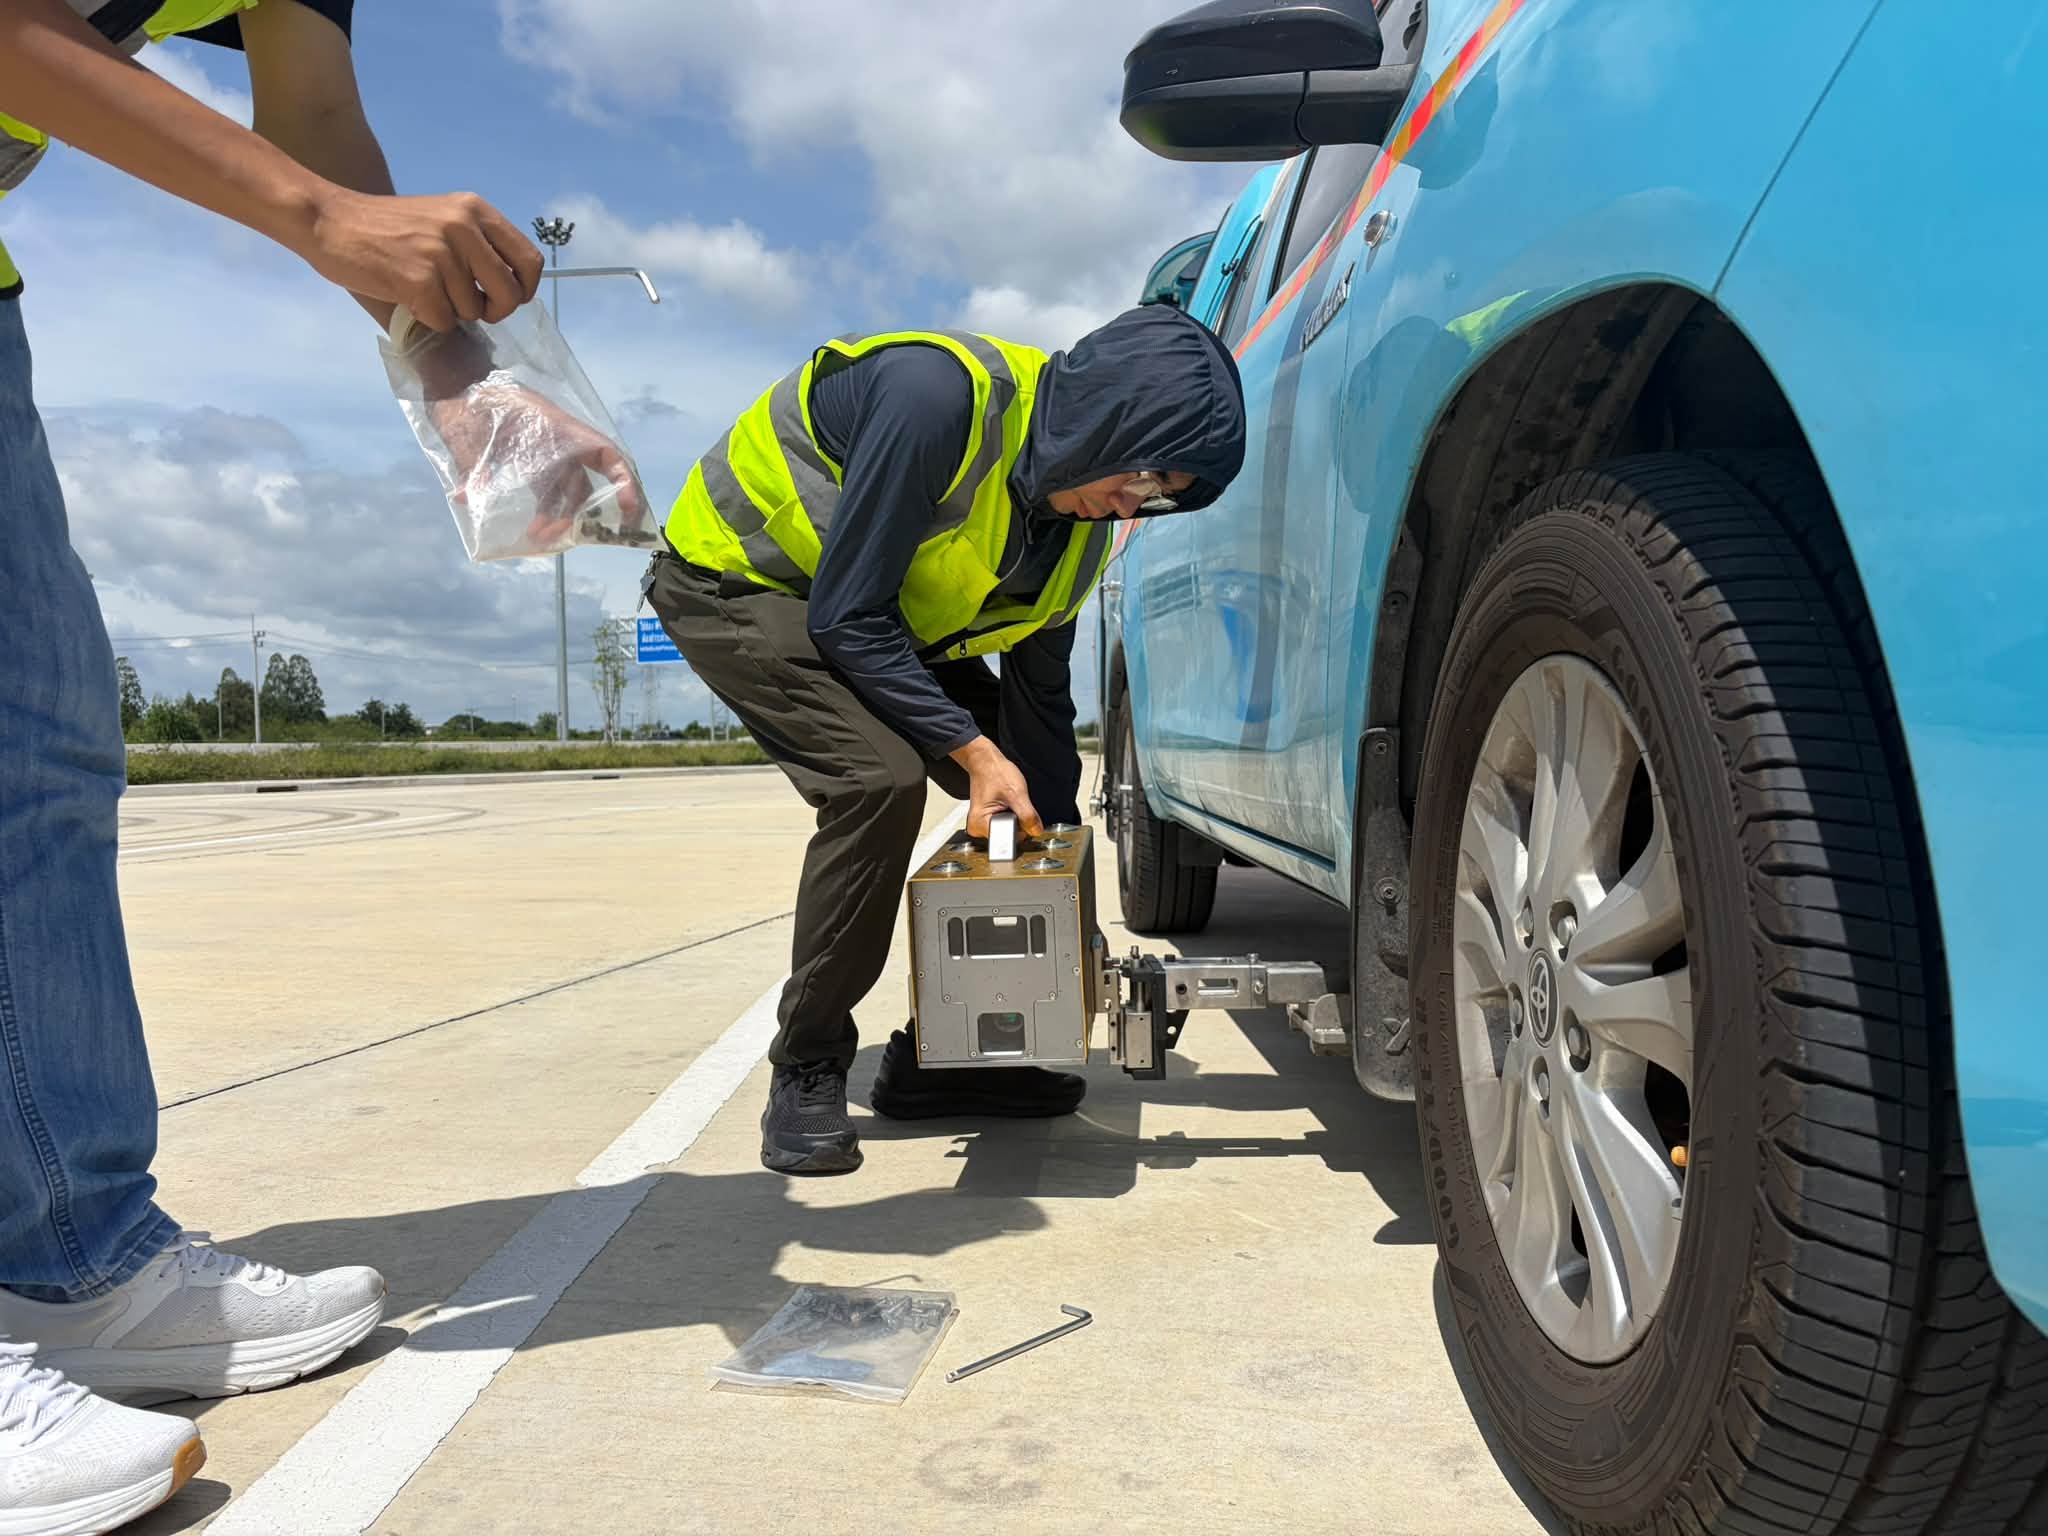
The objective of conducting business in the sale of innovative engineering products. This includes equipment for surveying and data collection for planning and managing infrastructure.
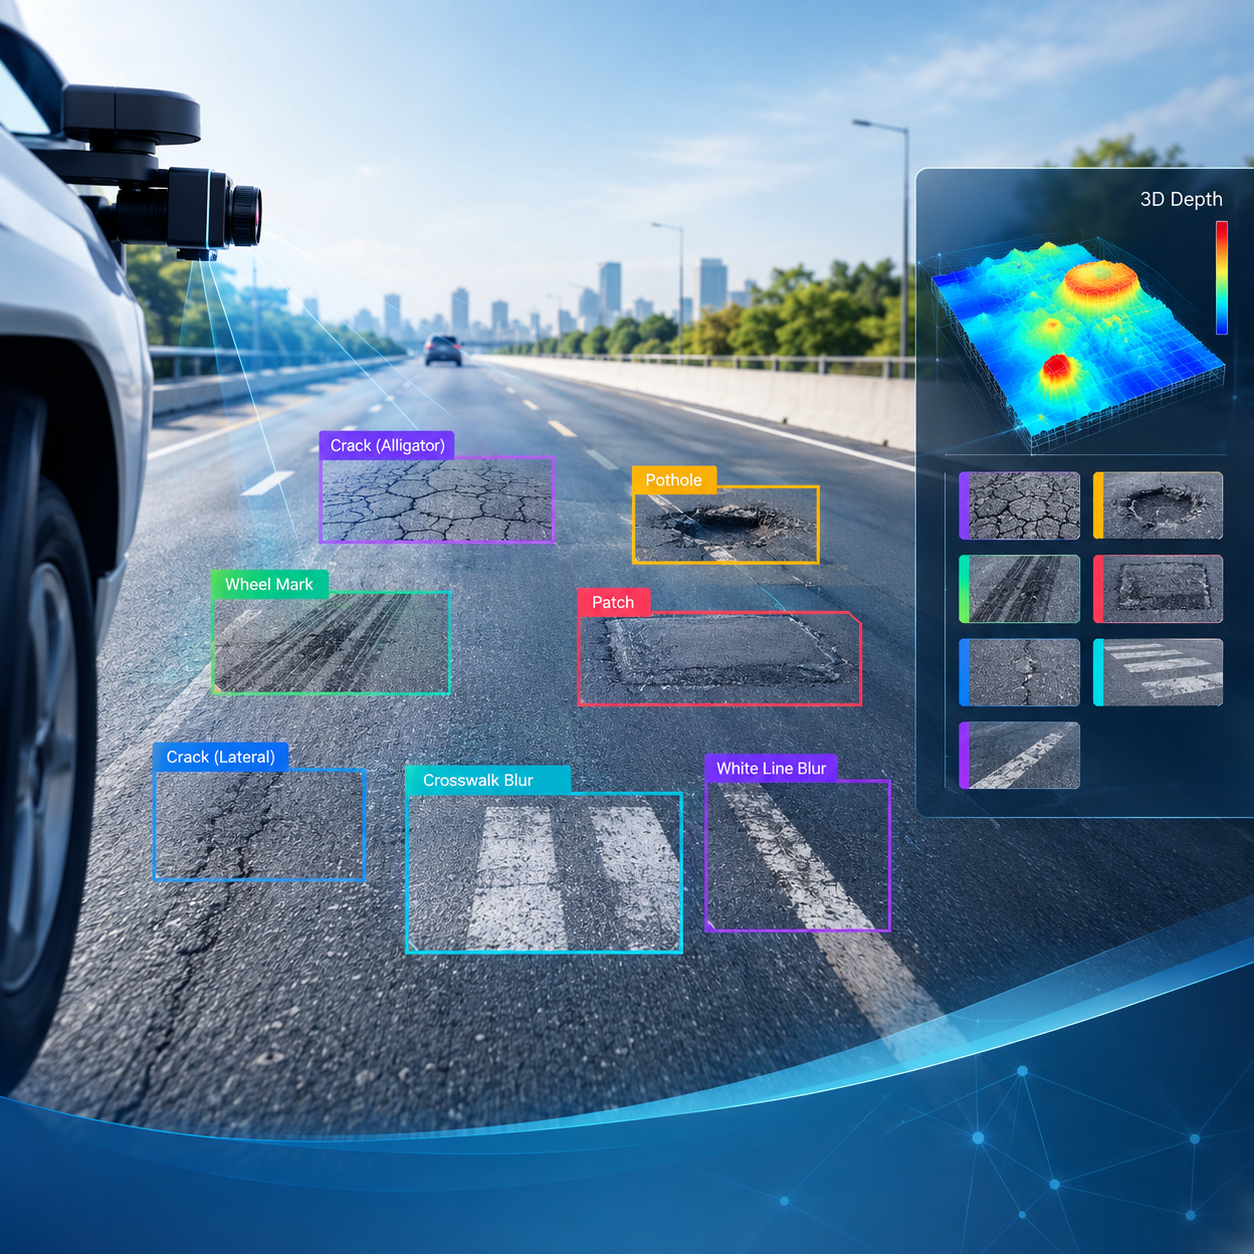
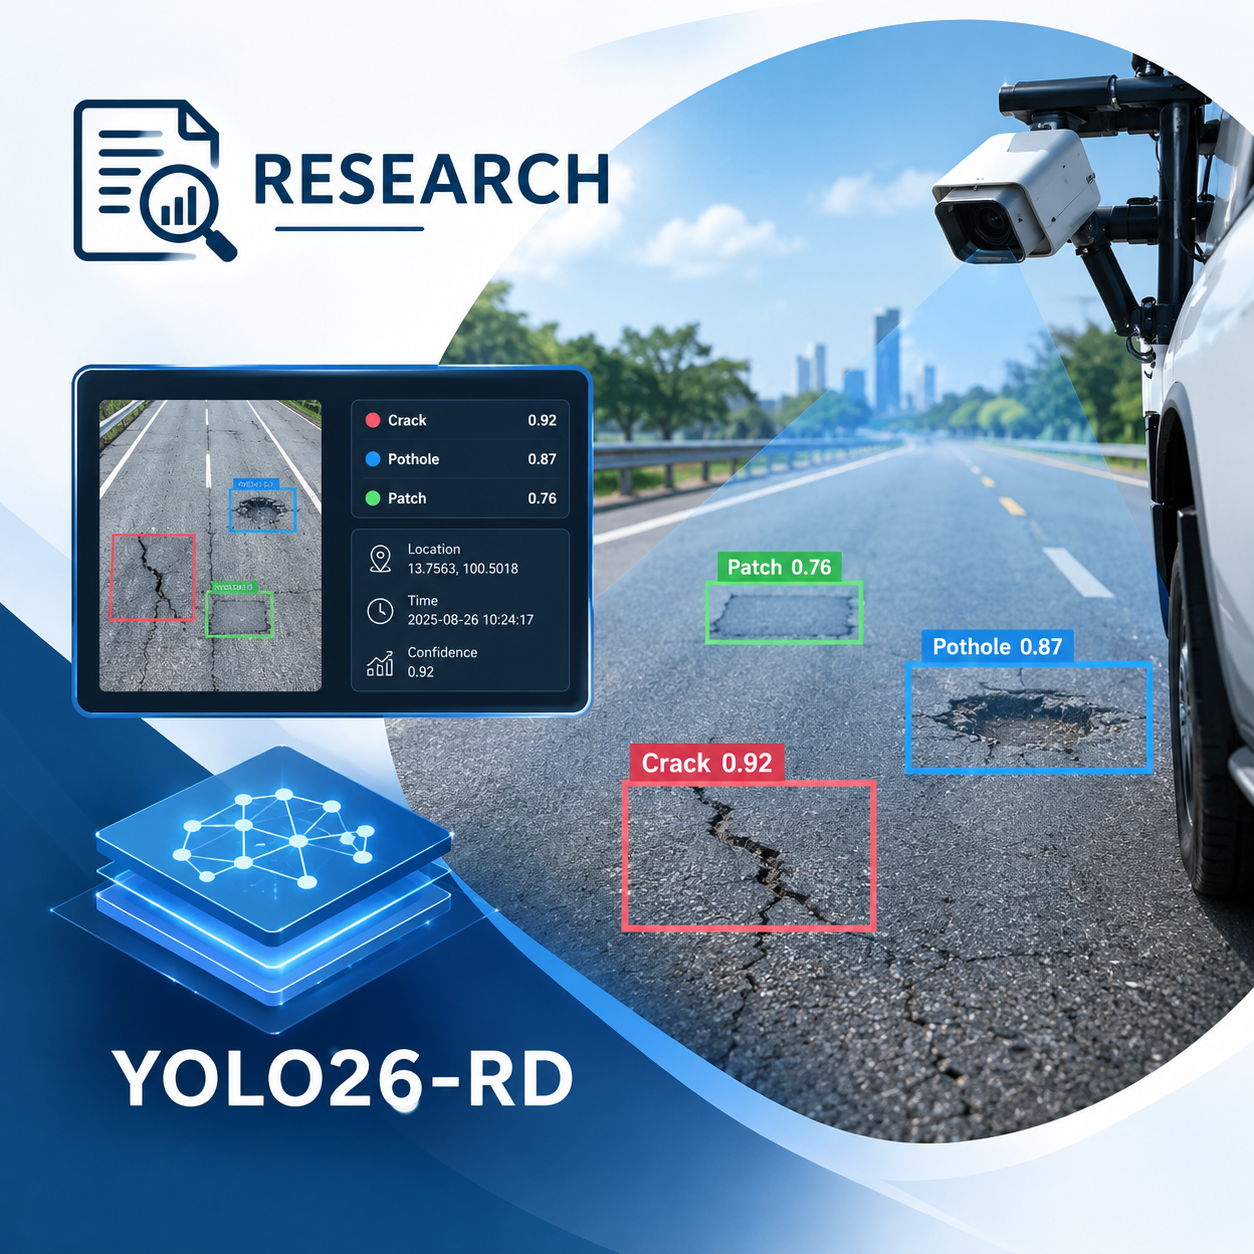
The study develops YOLO9tr, a lightweight object detection model for real-time pavement damage detection. The system identifies seven types of damage: lateral wheel marks, lateral cracks, alligator cracks, patching, potholes, crosswalk blur, and white line blur.
A grayscale-based depth estimation technique is also developed to estimate damage dimensions at distances of 3.5–7 meters without requiring specialized depth sensors. Experimental validation achieved a Mean Absolute Percentage Error (MAPE) of 19.4% for damage size estimation, while the proposed model can process images at speeds of up to 136 FPS.
The approach can operate with standard automotive-grade cameras and provides detection and measurement capabilities that can support road condition assessment, maintenance planning, resource allocation, and road infrastructure management.